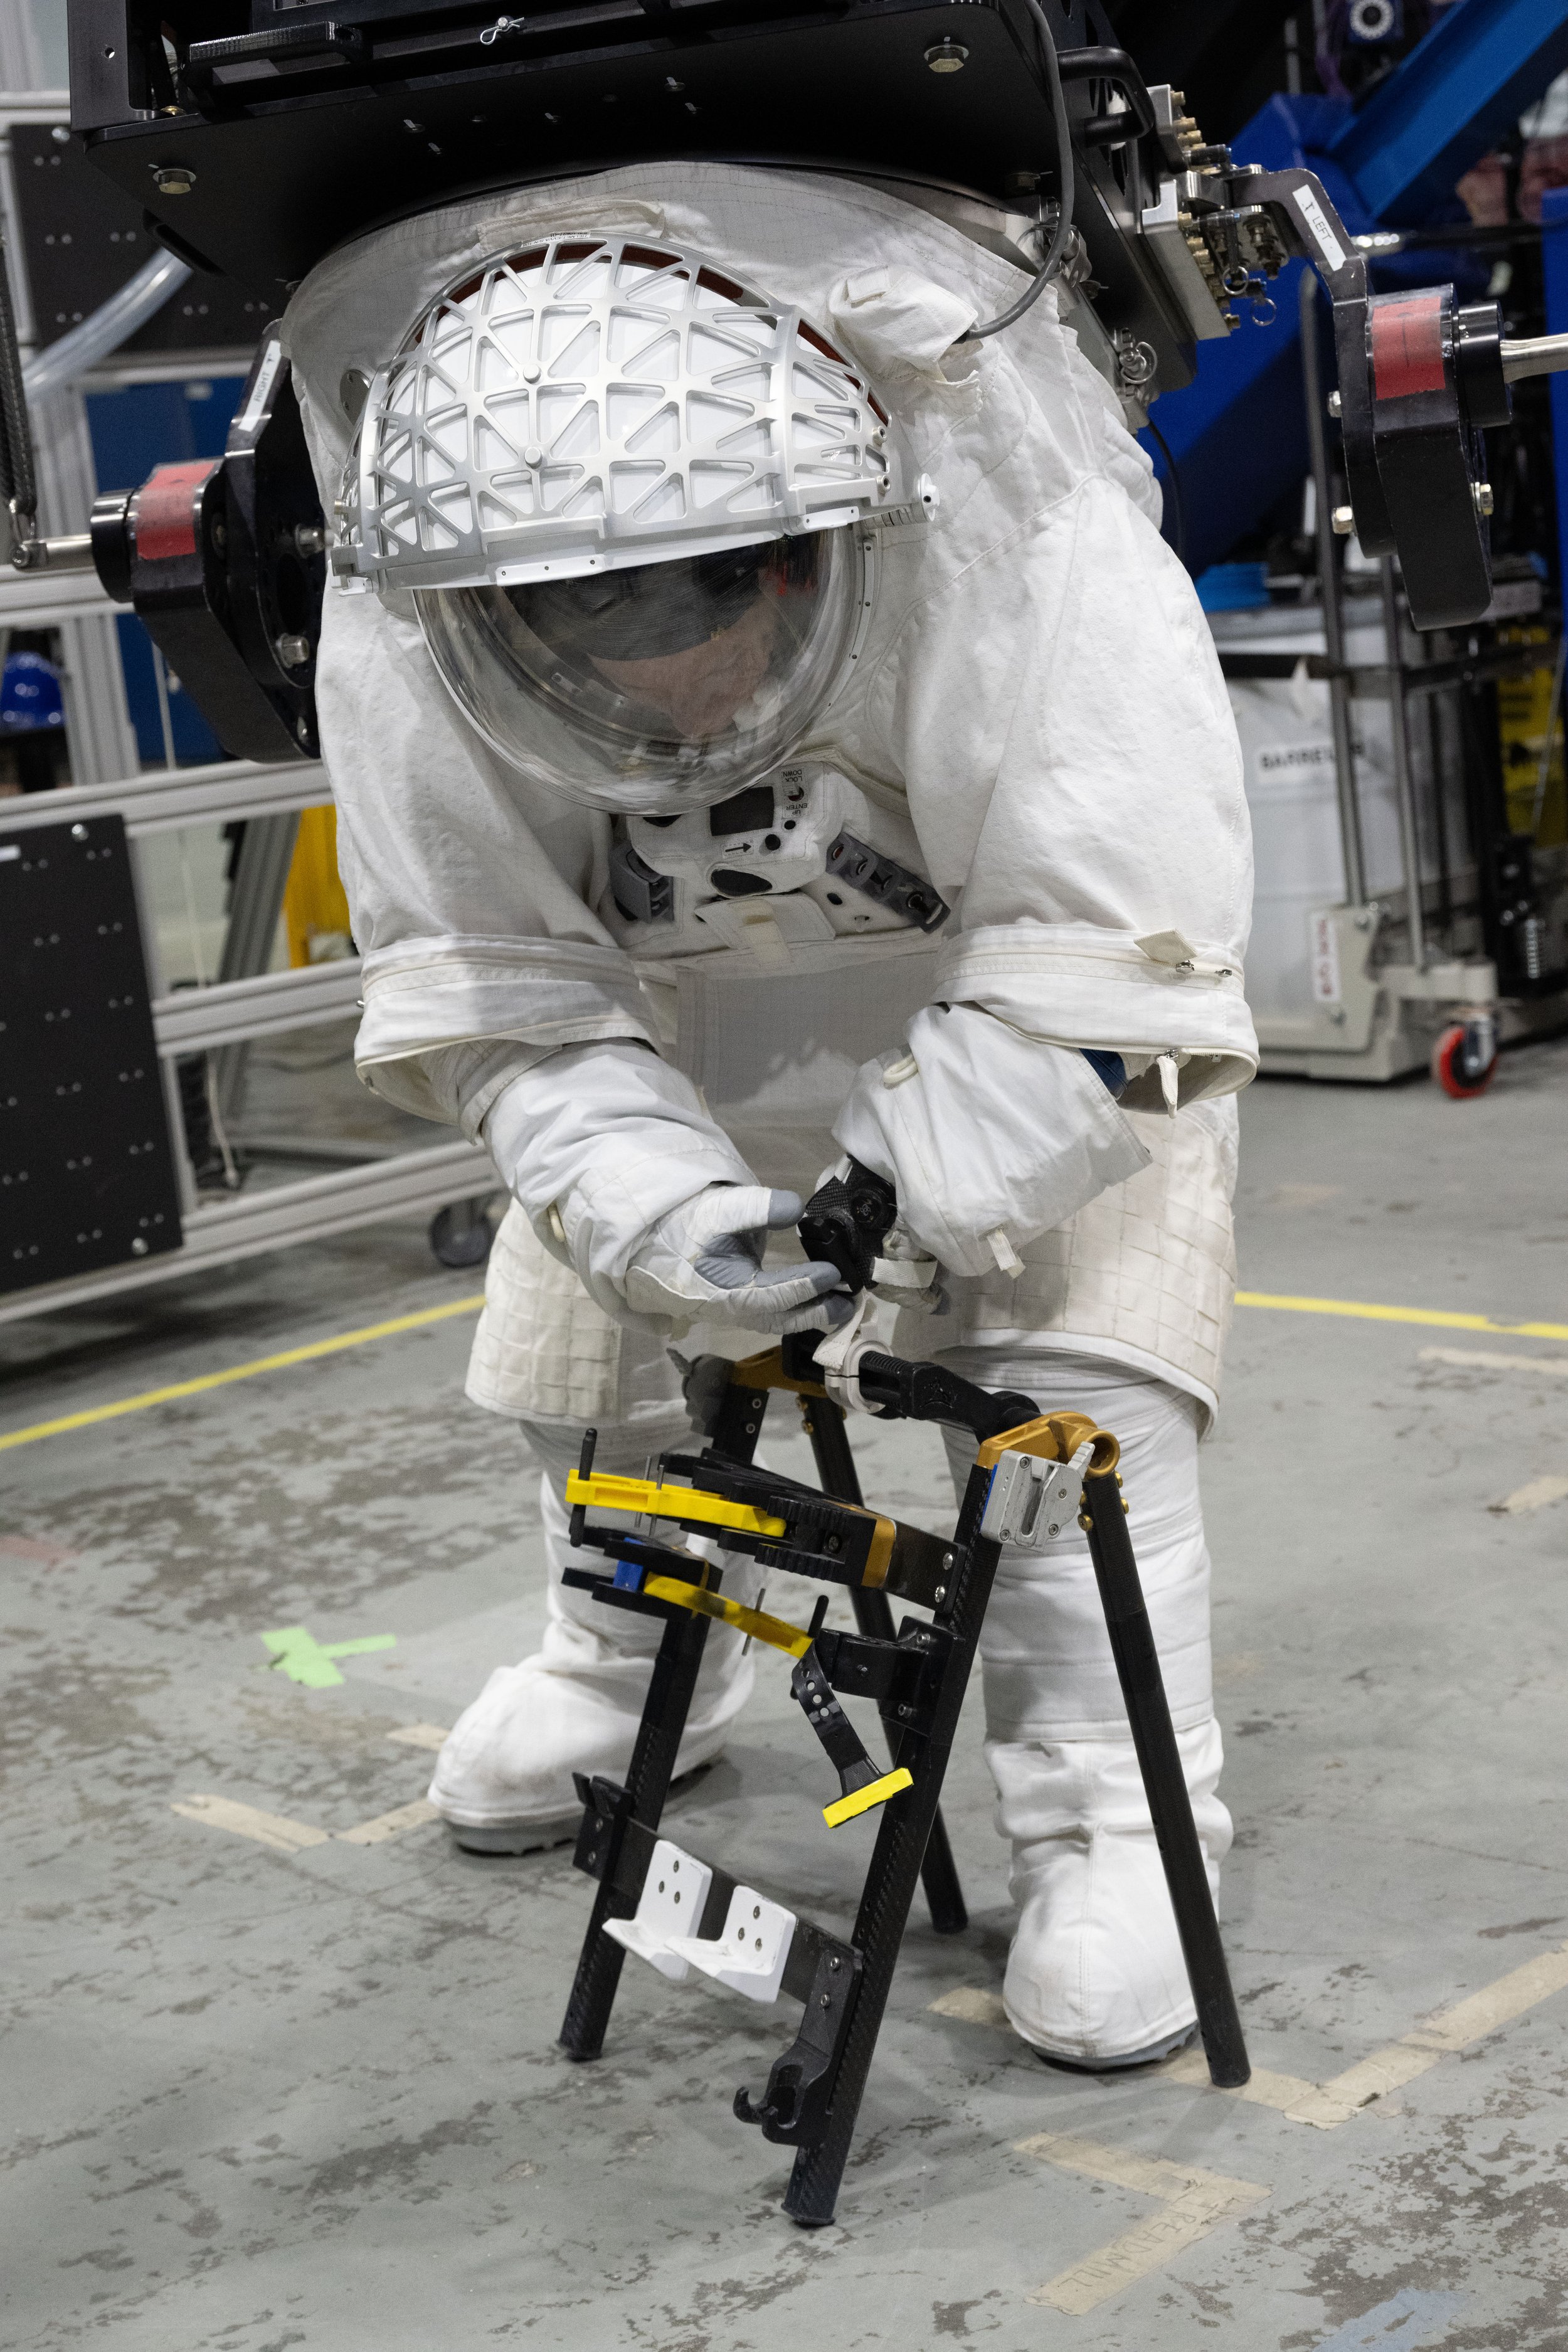
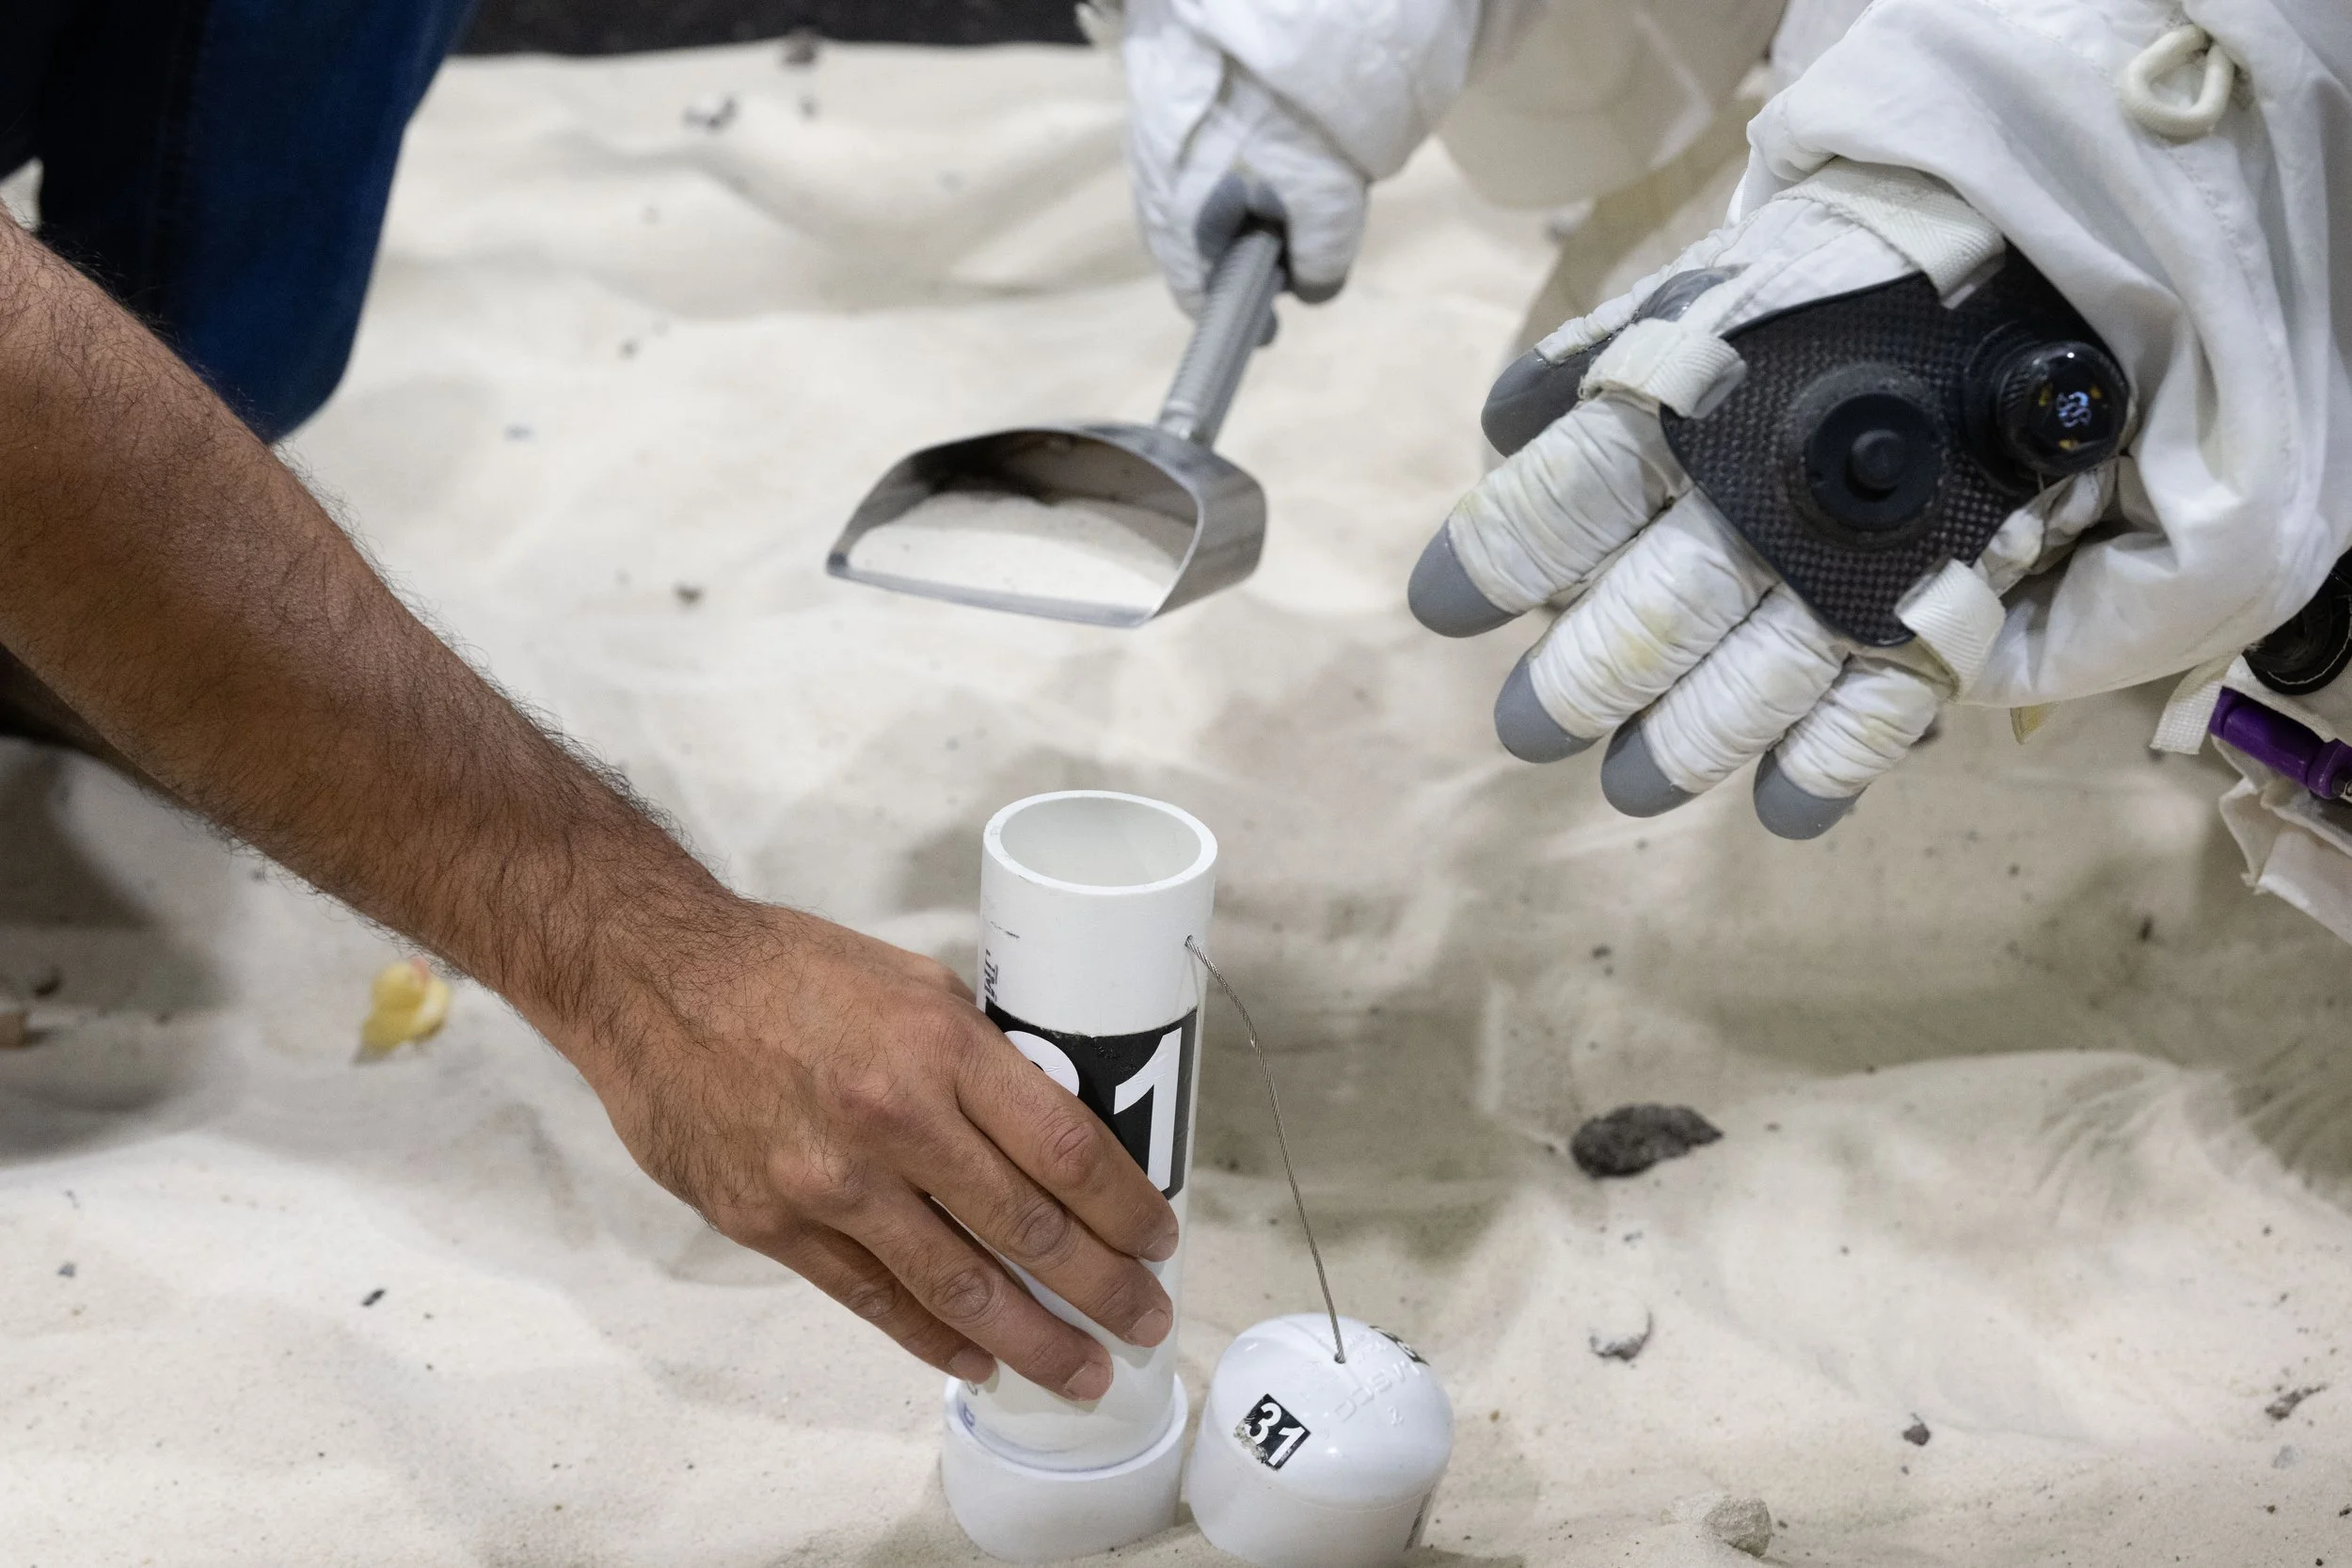
xPGS Passive Offload Strap
It is difficult to grasp tools against a pressurized glove. To mitigate this, I designed a prototype that soft-attaches to the outside of the glove. The goal is to bear a 40 lbs load without restricting hand mobility while being don/doffable after suit pressurization.
Ver. 1 is PLA, 3D-printed around a ball bearing that holds a hook which interfaces with the frame of the tool easel. Webbing is tensioned around the glove. Test subjects experienced no mobility interference but noted that the lack of regional strap tension altered the shape of the pressurized glove at the palm.
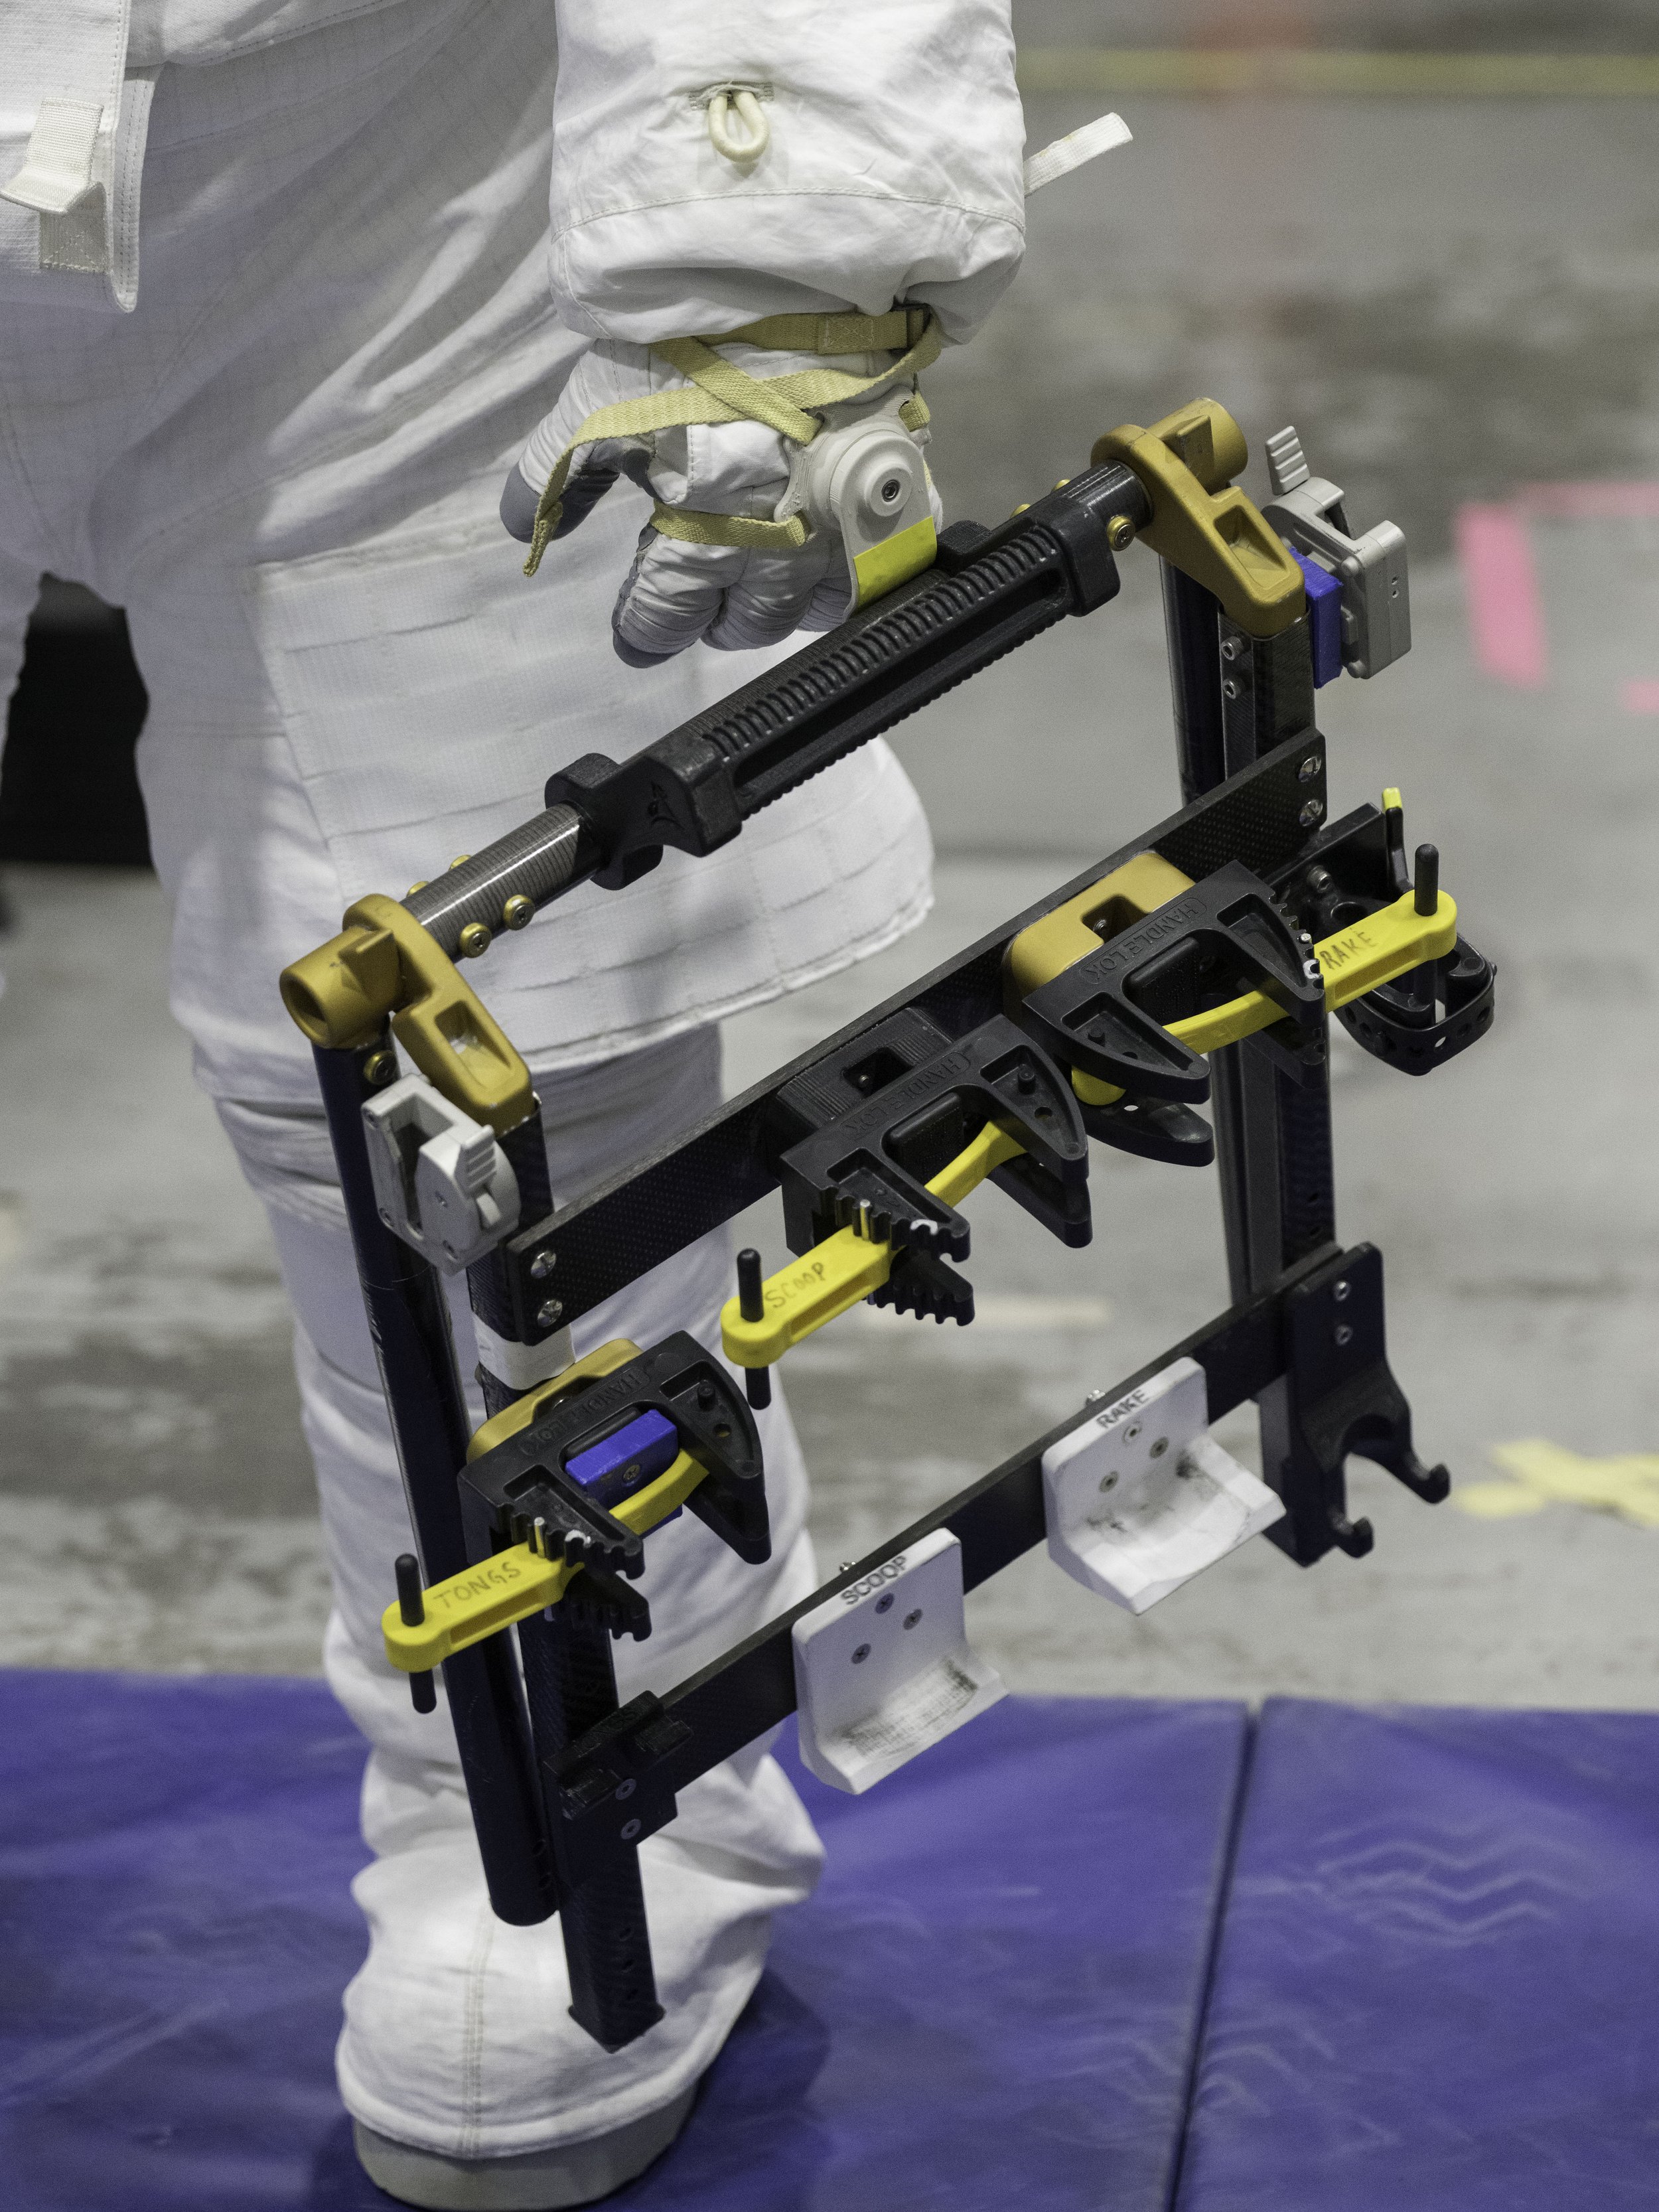
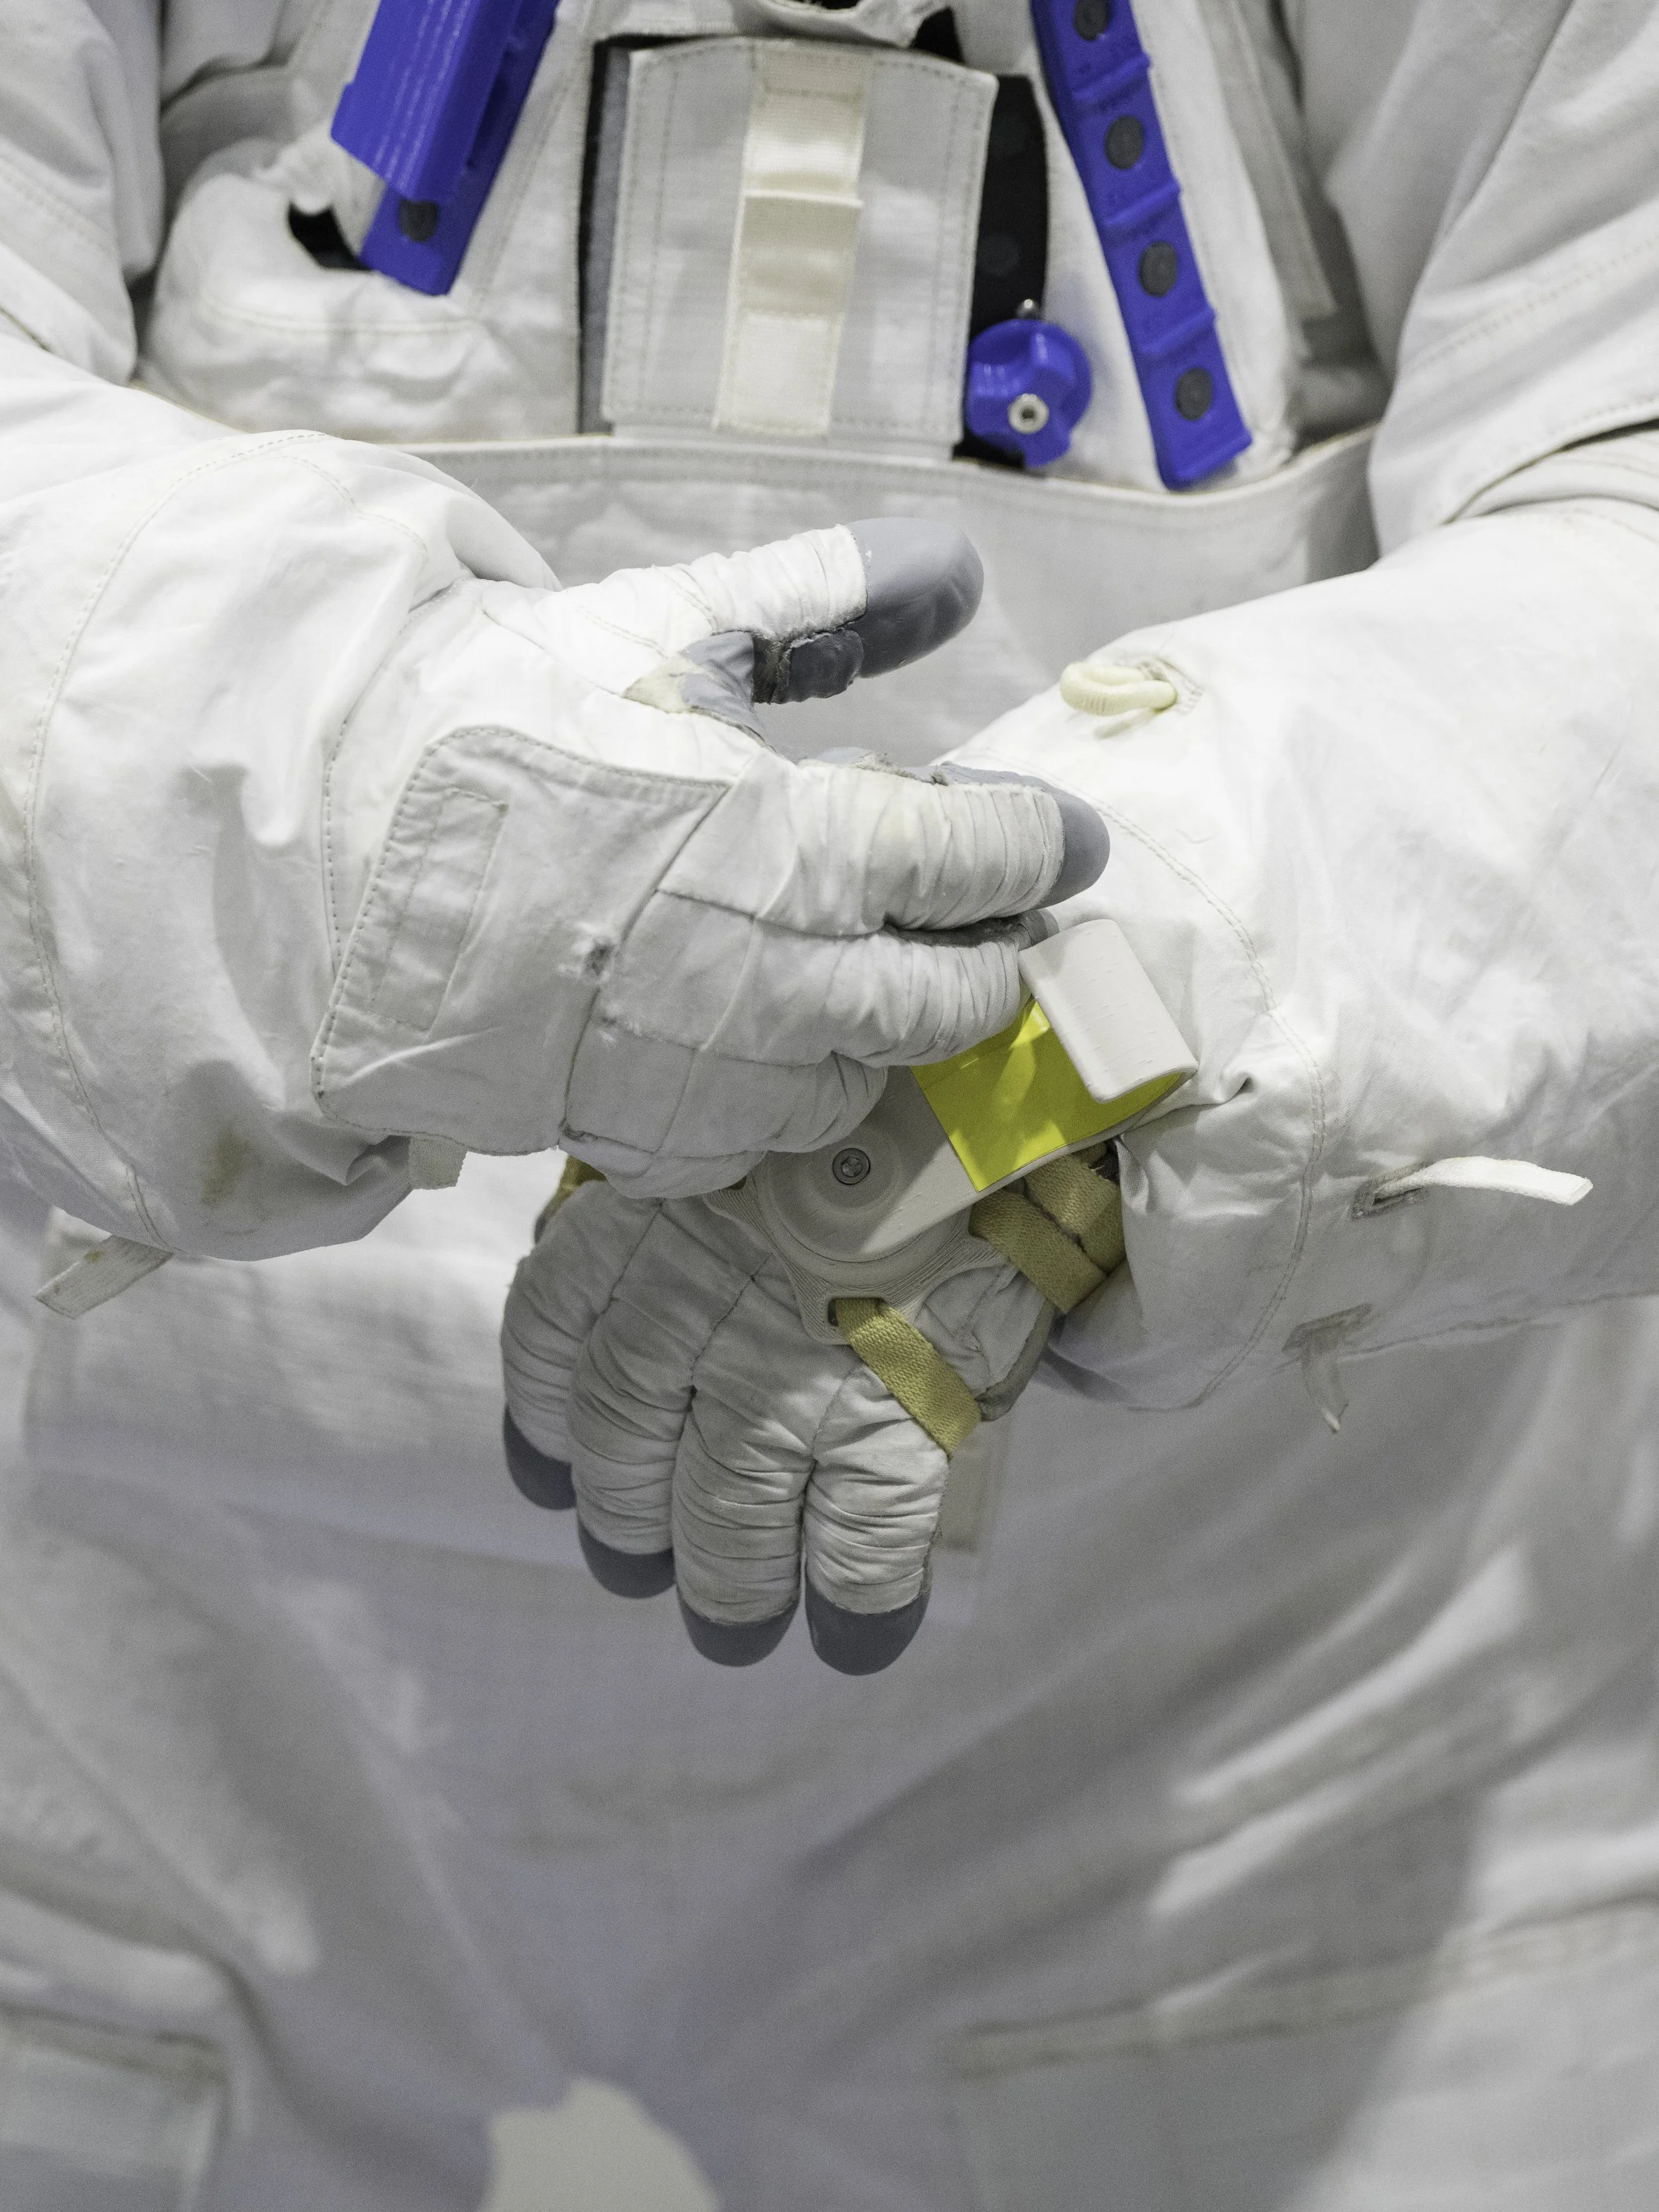
Ver. 2 is a custom-molded carbon fiber composite to achieve a lower profile and lighter weight.
This is a ground-testing configuration, since carbon fiber epoxy would not fare well when exposed to UV radiation and low temperatures.
Instead of a hook, it incorporates a Fidlock Snap fastener that interfaces with its corresponding buckle. That buckle is attached to a removable clamp that connects to the easel handle.
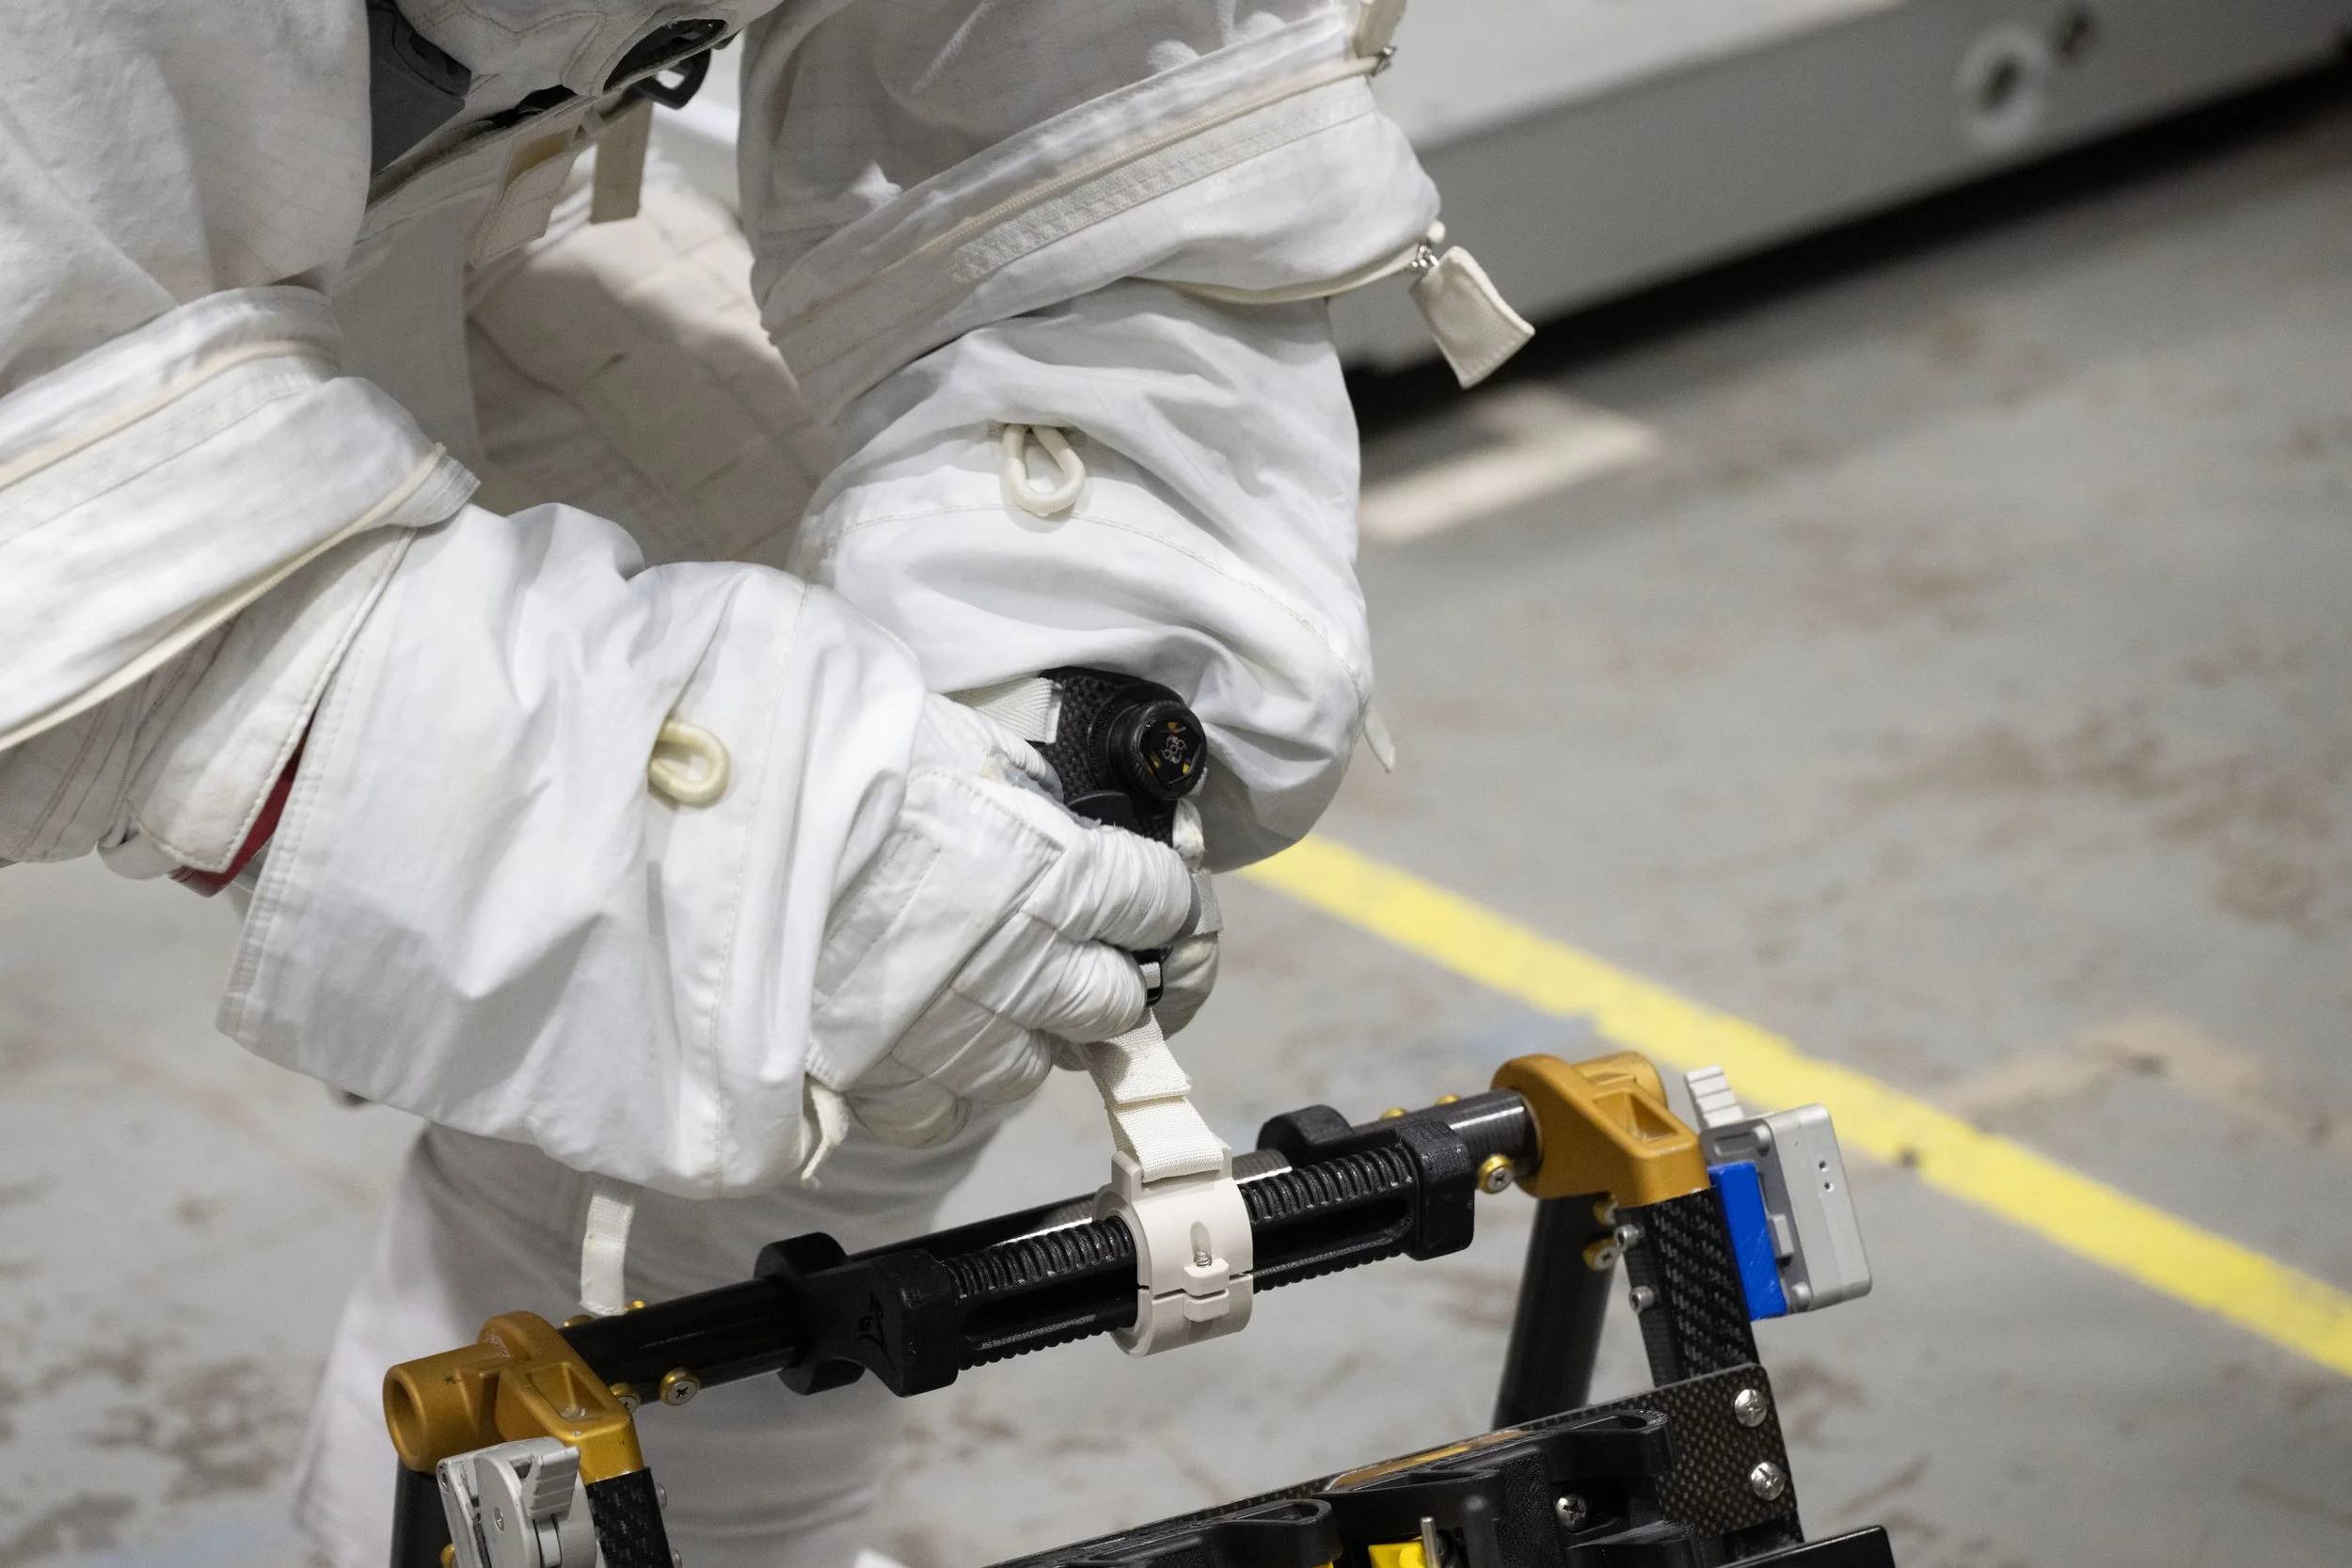
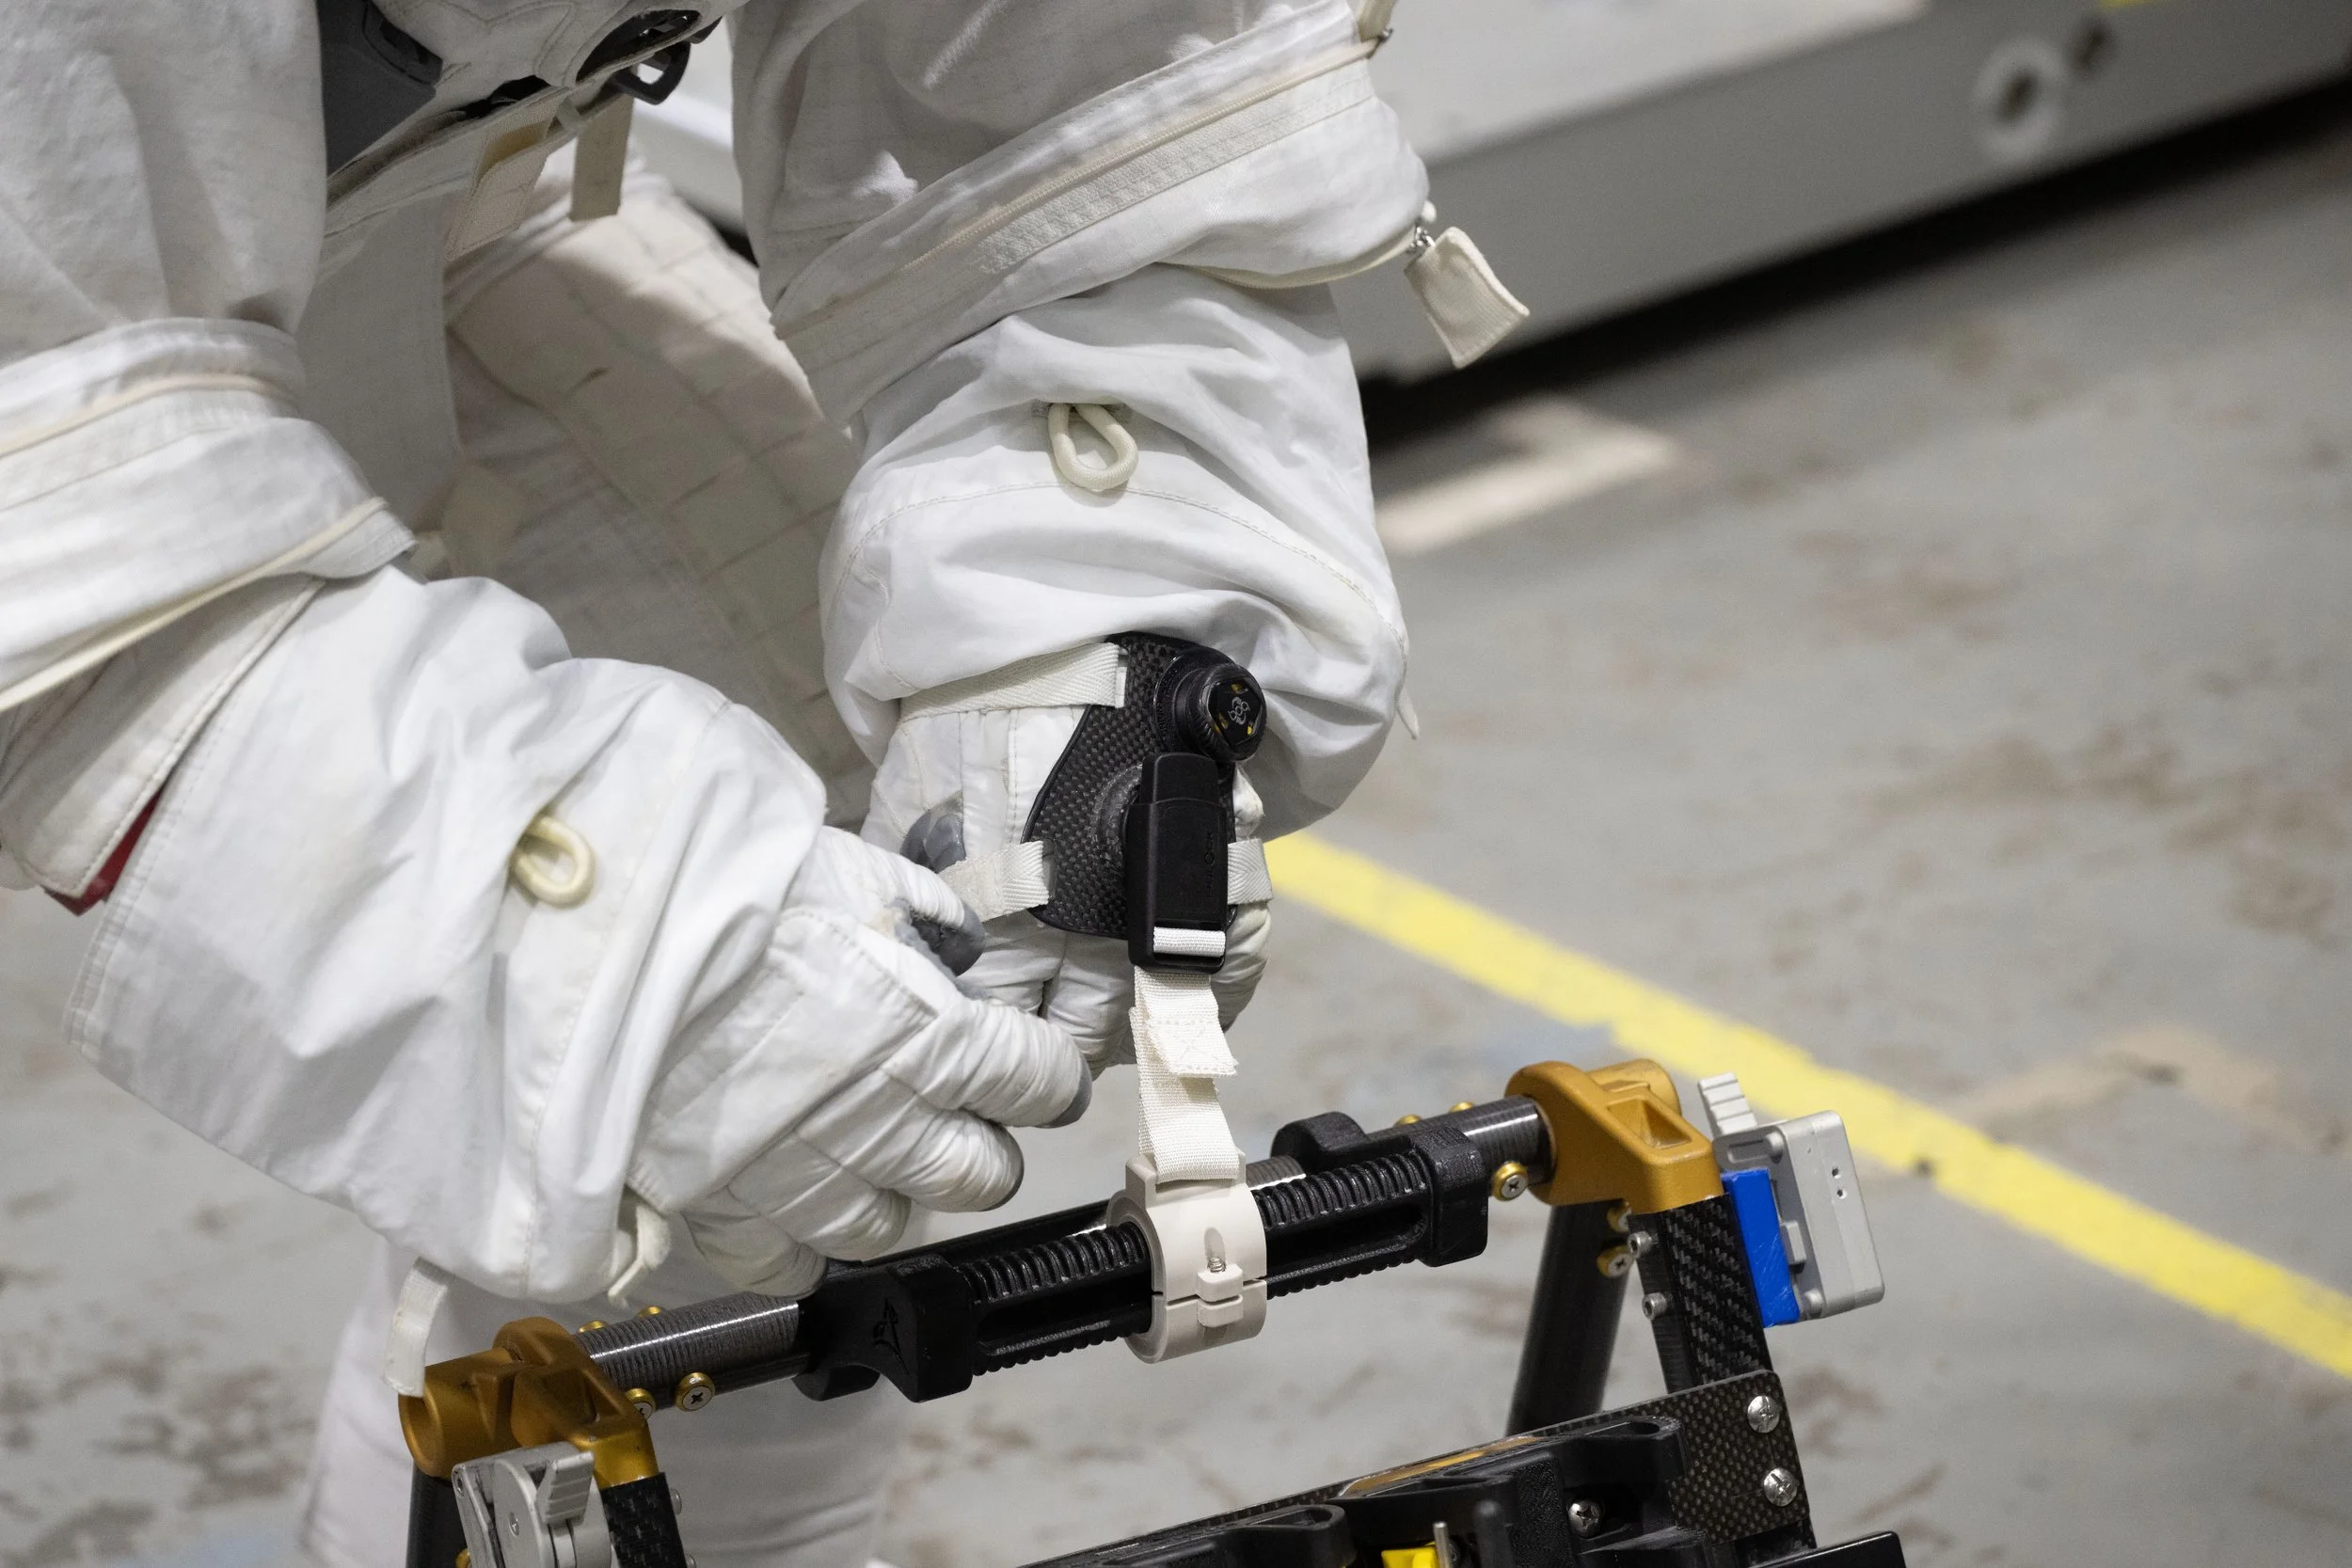
A BOA fastener is added for an easier don/doff experience. It tightens against the pressure at the wrist and bears the load of attachments. The palm strap fastens using hook-and-loop and stabilizes the POS.
Having different fasteners at the wrist + palm allows crew members to isolate the tension of the POS.